Orbital Grappling Arms: Satellite Capture Tech 2026

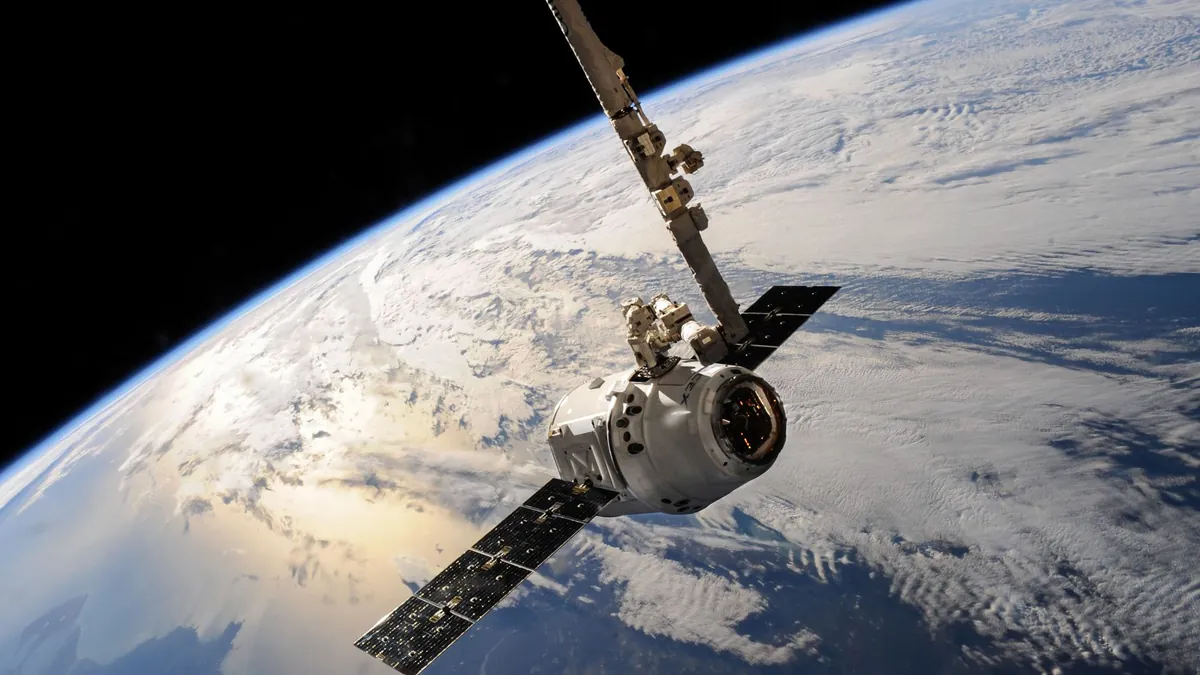
Low Earth orbit is becoming dangerously congested, with over 27,000 tracked debris objects threatening active satellites worth billions of dollars. Space agencies and private operators alike are racing to develop precision capture systems capable of neutralizing this growing orbital hazard. In 2026, orbital grappling arms satellite technology has emerged as the most technically credible solution on the table.
Yet the engineering challenge is far more brutal than most headlines acknowledge. Capturing a tumbling, uncooperative object in microgravity — with millisecond-level reaction requirements — pushes robotic systems to their absolute limits. The friction between ambition and physical reality is where this technology either proves itself or fails catastrophically.
Robotic Arm Architecture Is the True Engineering Battleground
Modern orbital grappling arms are built around multi-joint manipulator systems, typically featuring 6 or 7 degrees of freedom to replicate human wrist and elbow mobility in 3-dimensional space. Engineers prioritize lightweight composite materials — often carbon-fiber-reinforced polymers — to keep arm mass below 45 kilograms while maintaining structural rigidity under capture-force loads. These designs must also survive extreme thermal cycling, swinging between -120 and +150 degrees Celsius across each 90-minute orbital pass.
End-effector design is equally critical, with tendon-driven grippers and magnetic capture pads both competing for dominance in current prototypes. Missions targeting legacy satellites face a specific problem: those objects were never designed with grapple fixtures, forcing arms to improvise contact points on antenna mounts or thruster nozzles. This architectural reality is reshaping how engineers approach military orbital monitoring platforms that may eventually require in-orbit servicing.
Sensor Fusion and Debris Removal Demand Flawless Real-Time Judgment
Orbital grappling arms satellite technology depends heavily on sensor fusion — combining LIDAR, stereo vision cameras, and inertial measurement units to build a real-time 3D model of the target object’s spin rate and trajectory. A miscalculation of even 2 degrees in approach angle can result in a collision that generates new debris rather than removing it. Active debris removal missions therefore demand autonomous guidance systems capable of sub-centimeter positional accuracy at closing speeds under 0.05 meters per second.
The regulatory environment adds another layer of complexity that engineers cannot afford to ignore. No binding international framework currently governs who has legal authority to physically contact another nation’s satellite, even a defunct one. Analysts tracking deep-space mission challenges warn that unresolved jurisdictional ambiguity could stall deployment timelines well beyond 2028 for multinational debris removal programs.
Orbital grappling arms represent one of the most consequential technological frontiers of this decade, sitting at the intersection of robotics, space law, and national security. Getting the engineering right matters enormously, but so does building the international coordination frameworks that allow these systems to operate without triggering diplomatic crises. Share your thoughts in the comments — do you believe international space law can evolve fast enough to match the pace of this technology?